Problem Description
This example is adapted from the Simpack tutorial on flexible bodies using
co-simulation (see SIMPACK_Tutorial_flex_abaqcosim.zip on the
Simpack media). You do not need Simpack because we provide the generated results
file with this example.
The Simpack model consists of an automotive front axle with a flexible control arm as
shown in Figure 1. During the
first 0.25 sec, the front axle is accelerated to a velocity of 10 m/sec, and then
the speed is kept constant.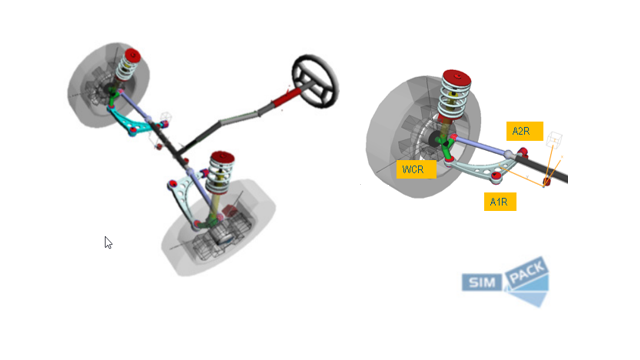
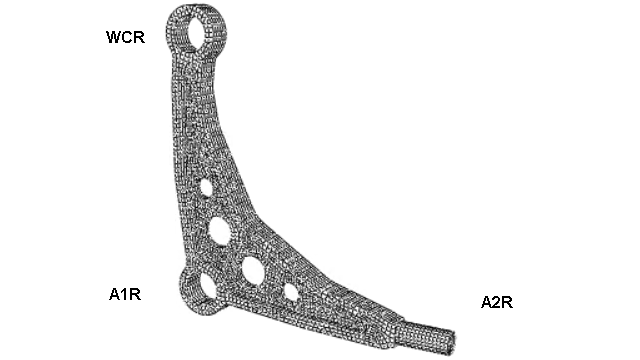
We perform a detailed finite element analysis of the control arm, where displacements and rotations of the left control arm computed by Simpack are imported and applied at three discrete locations shown in Figure 2. The imported displacement and rotation are applied using distributing constraints in Abaqus.